Perception Kits · AMR Navigation Kit
HyperEdge 700R – Warehouse AMR Essential Perception Kit
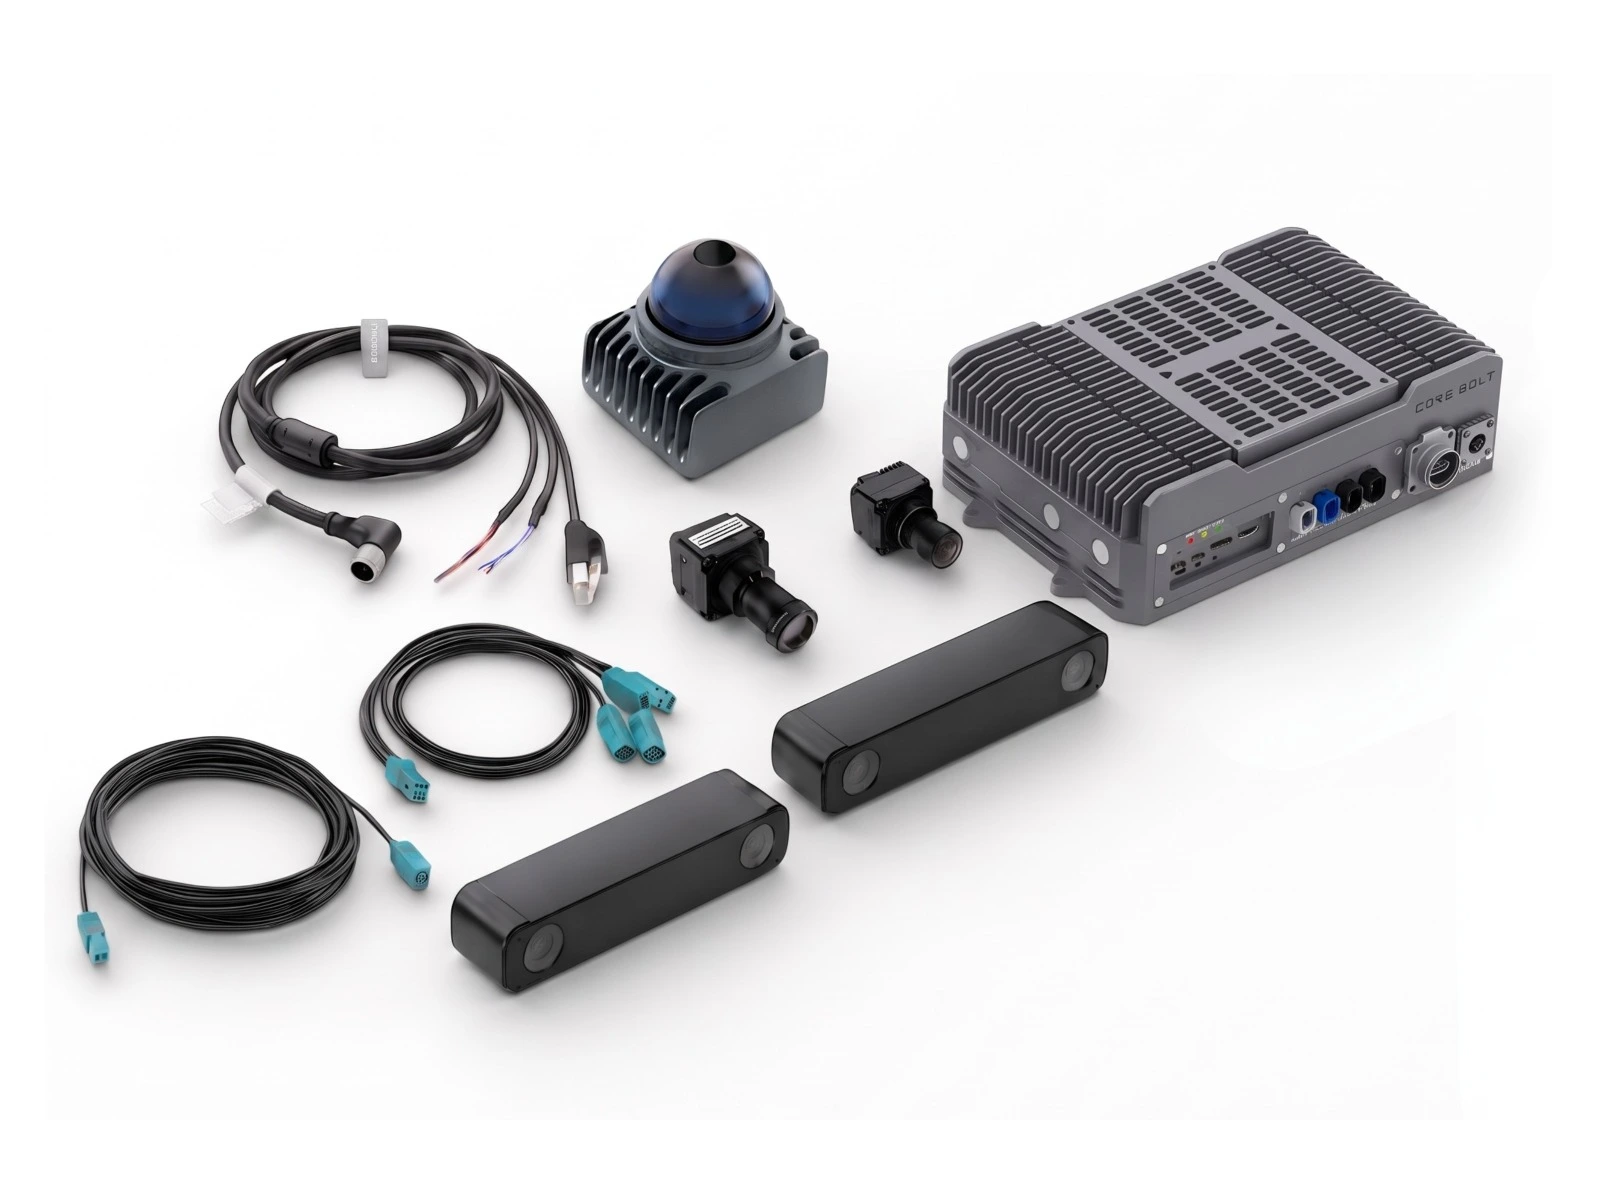
The HyperEdge 700R AMR Essential Perception Kit is a pre-matched hardware kit for warehouse autonomous mobile robots (AMRs) and AGVs. It combines CORE BOLT's HyperEdge 700RGT Edge AI Computer (NVIDIA Jetson Orin NX 16GB, up to 157 TOPS) with a Livox Mid-360S 3D LiDAR and a Stereolabs ZED X GMSL2 stereo camera, for 360° obstacle awareness, aisle navigation and close-range depth sensing.
Specifications
Technical Specifications
HyperEdge 700R — AMR Navigation Kit (Essential) — System Configuration
| Parameter | Specification |
|---|---|
| Product Type | Integrated AI Perception Kit |
| Kit Code | CB-AMR-105 |
| Primary Compute | CoreBolt HyperEdge 700RGT |
| Compute Configuration | NVIDIA Jetson Orin NX 16GB |
| Maximum AI Performance | Up to 157 TOPS |
| 3D LiDAR | Livox Mid-360S |
| Cameras / Vision | Stereolabs ZED X |
| Sensor Interfaces | Ethernet + GMSL2 / FAKRA-Z |
| Perception Functions | 360° aisle navigation and obstacle detection with close-range stereo depth |
| Deployment Environment | Indoor, climate-controlled warehouse and production floors |
| Typical Applications | Warehouse AMRs and AGVs that need aisle navigation and docking |
HyperEdge 700RGT — AI Edge Computer
| Parameter | Orin Nx 16gb |
|---|---|
| AI Performance | 100 TOPS |
| AI Performance — Super Mode | 157 TOPS |
| GPU | 1024-core NVIDIA Ampere GPU, 32 Tensor Cores |
| CPU | 8-core Arm Cortex-A78AE |
| Memory | 16GB 128-bit LPDDR5 102.4 GB/s |
HyperEdge 700RGT — Interfaces & Environment
| Parameter | Specification |
|---|---|
| GMSL2 Camera Inputs | 8 × GMSL2 (FAKRA-Z), 1-to-4 splitter cables included |
| Ethernet | 1 × M12 Gigabit Ethernet (independent IP) + 4 × M12 Gigabit Ethernet, PoE optional |
| USB | 2 × USB 3.0 Type-A, 1 × Type-C debug |
| Serial / CAN / GPIO | RS-232, RS-485, CAN-FD, SPI-CAN-FD, isolated GPI / GPO |
| Time Sync | NTP, PPS input / output |
| Expansion | Mini PCIe (4G), M.2 3052 Key B (5G), M.2 2280 Key M (NVMe SSD), M.2 2230 Key E (Wi-Fi / BT) |
| Power Input | 9–36 V DC with ACC ignition control (M16 6-pin) |
| Ingress Protection | IP65 |
| Operating Temperature | -20°C to +70°C (Orin NX) |
| Dimensions | 295 × 207.1 × 76.5 mm |
Livox Mid-360S — 3D LiDAR
| Parameter | Specification |
|---|---|
| LiDAR Type | Hybrid solid-state 3D LiDAR |
| FOV (H × V) | 360° × 59° (-7° to +52°) |
| Detection Range | 40 m @ 10% reflectivity (100 m cut-off) |
| Minimum Range | 0.1 m |
| Point Rate | 200,000 pts/s (first return) |
| Frame Rate | 10 Hz (typical) |
| IMU | Built-in |
| Interface | 100BASE-TX Ethernet |
| Power | 6.5 W typical, 9–27 V DC |
| Dimensions | 65 × 65 × 60 mm |
| Weight | 265 g |
| Operating Temperature | -20°C to +55°C |
| IP Rating | IP67 |
Stereolabs ZED X — GMSL2 Stereo Camera
| Parameter | Specification |
|---|---|
| Image Sensors | Dual 2.3 MP global shutter, 1920 × 1200 |
| Frame Rate | 60 fps @ 1920 × 1200; 120 fps @ 960 × 600 |
| Stereo Baseline | 120 mm |
| FOV | Up to 120° (2.2 mm lens) |
| Depth Range | 0.3 m to 20 m (2.2 mm lens) |
| Interface | GMSL2, FAKRA-Z, up to 15 m |
| Power | ~1.4 W, power over GMSL2 |
| IMU | Yes |
| Operating Temperature | -20°C to +60°C |
| IP Rating | IP67 |
| Weight | 239 g |
Integration & Connectivity
| Component | Interface | Connected To | Function |
|---|---|---|---|
| Livox Mid-360S | Ethernet (100BASE-TX) | HyperEdge M12 Ethernet | Aisle navigation & obstacle detection |
| Stereolabs ZED X | GMSL2 / FAKRA-Z | HyperEdge GMSL2 (4-in-1) | Close-range global-shutter stereo depth |
| Intel RealSense D457 (optional) | GMSL2/ FAKRA | HyperEdge GMSL2 (FAKRA-Z) | Mast-mounted pallet-pocket detection over coax |
| HyperEdge 700RGT | NVIDIA Jetson Orin | System Compute | AI Inference & Sensor Processing |
| NVMe SSD | M.2 Key M | HyperEdge 700RGT | Models, Applications & Data Storage |
Deployment Notes
| Parameter | Details |
|---|---|
| Customer-Supplied Items | Mast height encoder, load cell, 9-DOF IMU, wheel odometry |
| Ethernet Power | The Livox Mid-360S uses passive Ethernet — do not connect it to a PoE-sourcing port |
| Compute Variant | Supplied as the 700RGT (GMSL2) variant with Jetson Orin NX 16GB |
Overview
Essential AMR Perception Kit for Warehouse and Indoor Robotics
Discover the HyperEdge 700R warehouse AMR perception kit with Jetson Orin NX, Livox Mid-360S 3D LiDAR and ZED X stereo camera for AMR navigation and docking.
Warehouse robots need to see racks, people, pallets and docking stations reliably on busy production floors. The HyperEdge 700R kit gives robot developers a validated starting point: the compute, LiDAR and stereo camera are matched for interfaces, power and connectivity, so integration time goes into the robot application rather than hardware compatibility.
The HyperEdge 700RGT runs AI inference and sensor processing locally on an NVIDIA Jetson Orin NX 16GB module (100 TOPS, or 157 TOPS in Super Mode). The Livox Mid-360S provides a 360° × 59° 3D point cloud at up to 200,000 points per second, and the ZED X adds global-shutter stereo depth from 0.3 m to 20 m for docking and near-field obstacle detection. Together they provide the perception hardware for Physical AI applications in warehouse robotics.
The kit is supplied as hardware. Navigation, SLAM and perception software are developed or provided by the customer.
What's in the Kit
- 1 × CORE BOLT HyperEdge 700RGT Edge AI Computer (NVIDIA Jetson Orin NX 16GB)
- 1 × Livox Mid-360S 3D LiDAR
- 1 × Stereolabs ZED X GMSL2 stereo camera
- Kit code: CB-AMR-105
Key features
- Up to 157 TOPS of AI performance (Jetson Orin NX 16GB, Super Mode)
- 360° × 59° LiDAR field of view, 0.1 m minimum range, 40 m at 10% reflectivity
- Global-shutter stereo depth, 0.3–20 m, 120 mm baseline, up to 120° field of view
- 8 × GMSL2 (FAKRA-Z) camera inputs and 5 × M12 Gigabit Ethernet (PoE optional)
- RS-232, RS-485 and CAN-FD for robot controllers; PPS and NTP time sync
- IP65 compute, -20 °C to +70 °C, 9–36 V DC with ignition control
Applications
Warehouse automation, autonomous mobile robots, AGVs, material handling robots, smart manufacturing, industrial automation and machine vision. For 360° LiDAR coverage and a SICK S300 safety laser scanner, see the HyperEdge 900DR Advanced AMR Kit, or compare all AMR navigation kits.
Frequently Asked Questions
What is a warehouse AMR perception kit?
A warehouse AMR perception kit is a pre-matched set of computing and sensing hardware for an autonomous mobile robot. It usually combines an edge AI computer with 3D LiDAR and depth cameras, so developers can build navigation, obstacle detection and docking without validating each component separately.
What sensors are included in the HyperEdge 700R kit?
The kit includes a Livox Mid-360S 3D LiDAR for 360° environmental sensing and a Stereolabs ZED X GMSL2 stereo camera for close-range depth. Both connect to the HyperEdge 700RGT Edge AI Computer.
Why use both 3D LiDAR and a stereo camera on an AMR?
3D LiDAR gives accurate 360° distance measurements for mapping and obstacle detection. A stereo camera adds dense, close-range depth and visual detail for docking, pallet handling and objects the LiDAR may miss near the robot.
What is Physical AI in robotics?
Physical AI describes AI systems that sense and act in the physical world. In robotics, sensors such as LiDAR and cameras capture the environment, and an edge AI computer runs perception models locally, so the robot's software can plan and control its movement. Read more on why robots need perception.
Is navigation or SLAM software included?
No. The HyperEdge 700R is a hardware perception kit. SLAM, navigation and application software are developed or provided by the customer on the NVIDIA Jetson platform.
Can the HyperEdge 700R be used for AGVs?
Yes. The kit is designed for warehouse AMRs and AGVs that need aisle navigation, obstacle detection and docking in indoor environments.
What extra hardware is needed to deploy the kit?
The customer provides the mast height encoder, load cell, 9-DOF IMU and wheel odometry, plus the robot platform and its safety system.