360° × 59° field of view
Wide horizontal and vertical coverage helps mobile robots gather surrounding 3D scene data for navigation and environmental perception.
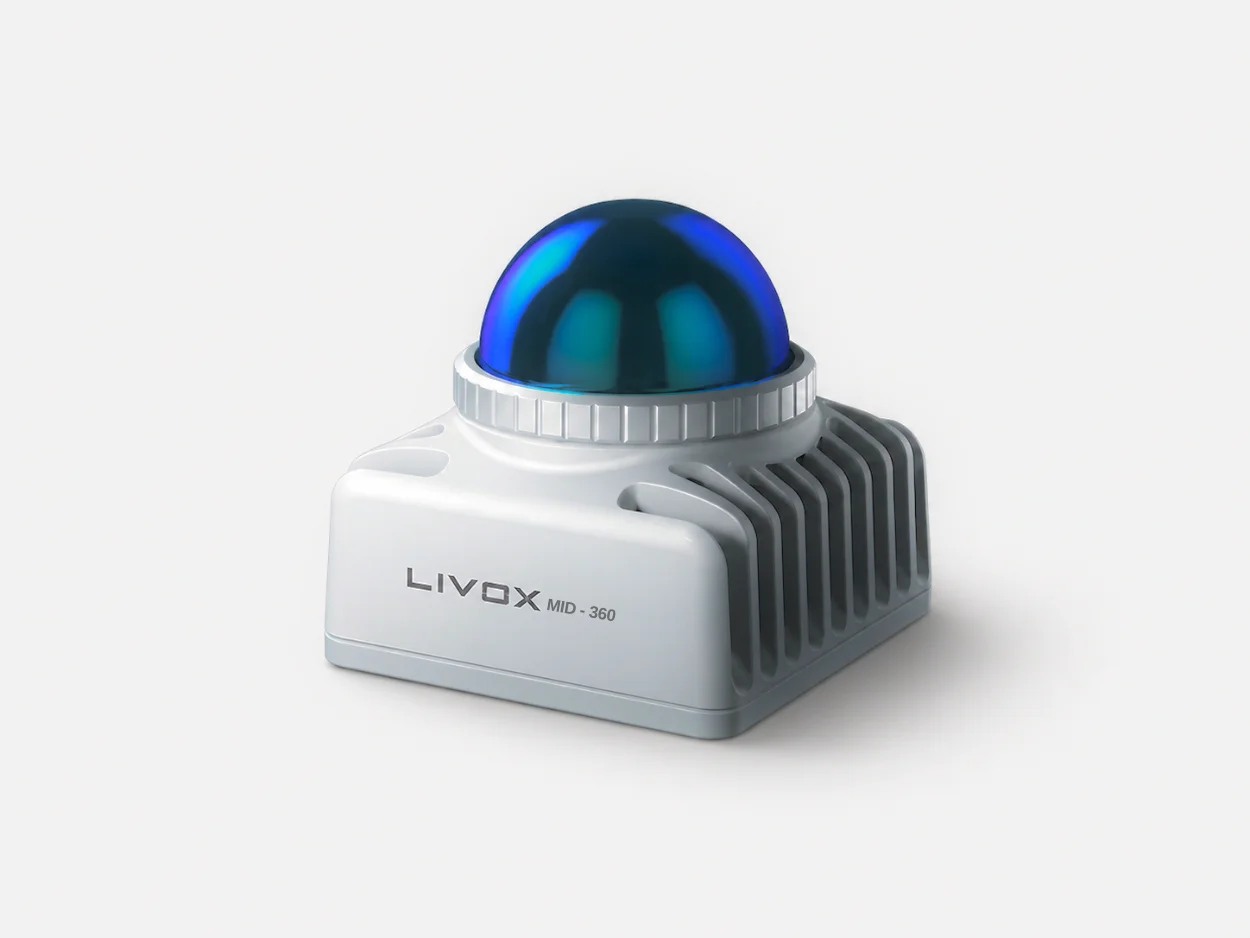
Compact 360° 3D LiDAR for mobile robots. A 360° × 59° field of view, up to 70 m range and an IP67 body in just 265 g, ready for mapping, localisation and obstacle avoidance.
The Livox MID-360S combines a 360° horizontal field of view with a compact form factor, giving mobile robot designers a point-cloud sensor to evaluate for mapping, localisation and obstacle-avoidance systems.
Wide horizontal and vertical coverage helps mobile robots gather surrounding 3D scene data for navigation and environmental perception.
At approximately 65 × 65 × 60 mm and 265 g, the sensor can be considered where mounting space and payload are important design constraints.
Use 3D LiDAR data with suitable mapping, SLAM and obstacle-avoidance software as part of a larger mobile-robot perception architecture.
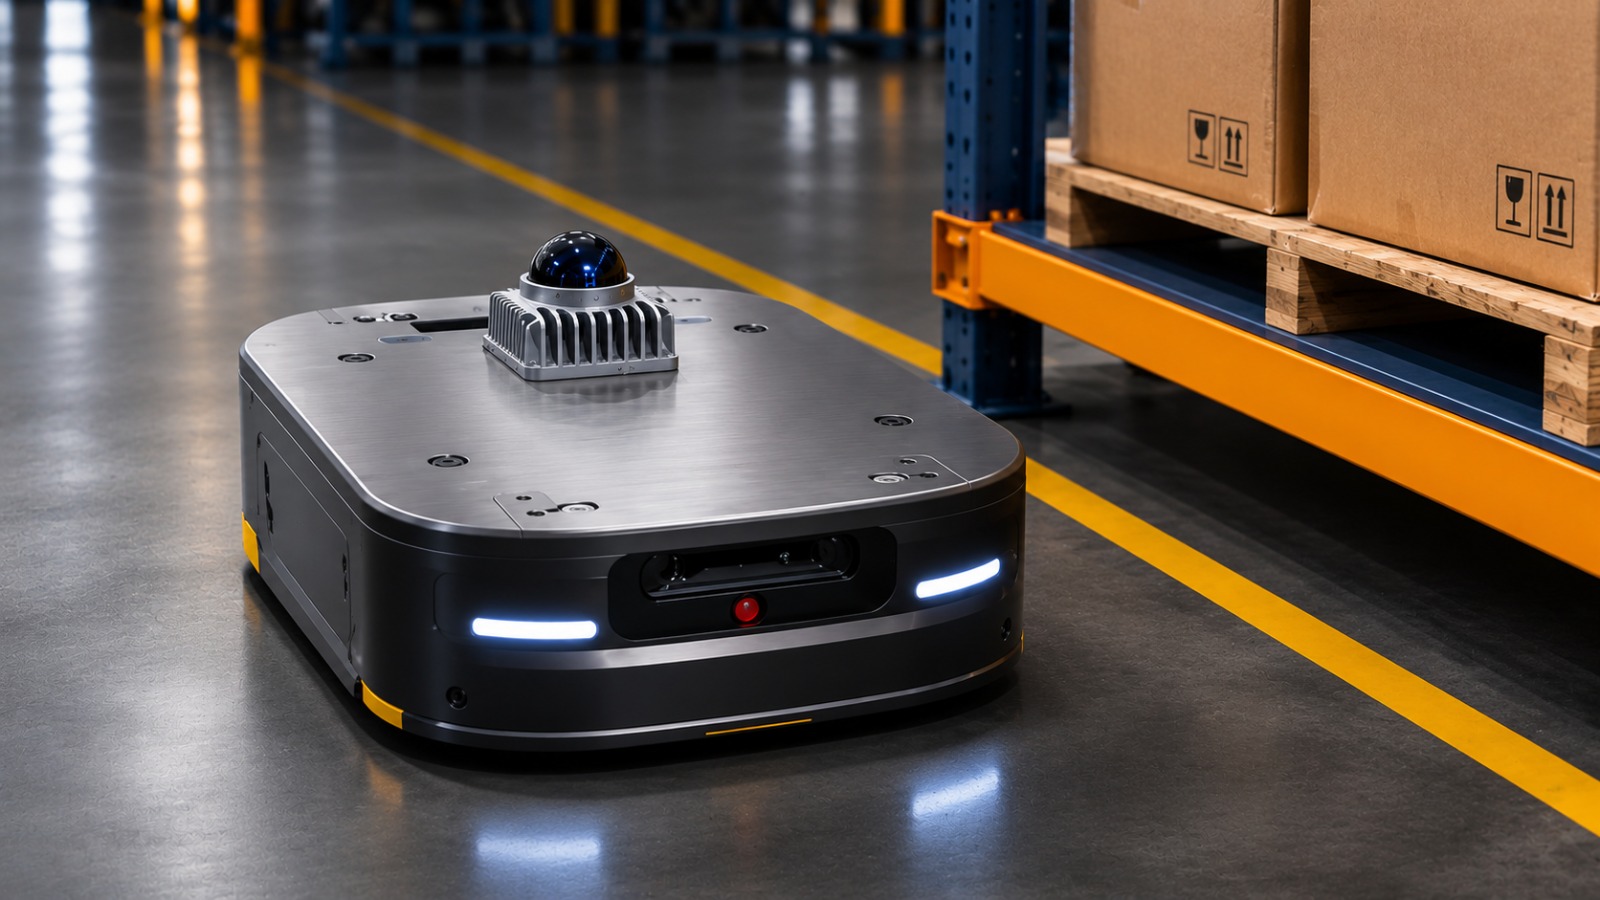
Use 3D point-cloud data to support mapping, localisation and obstacle awareness in warehouse operations.
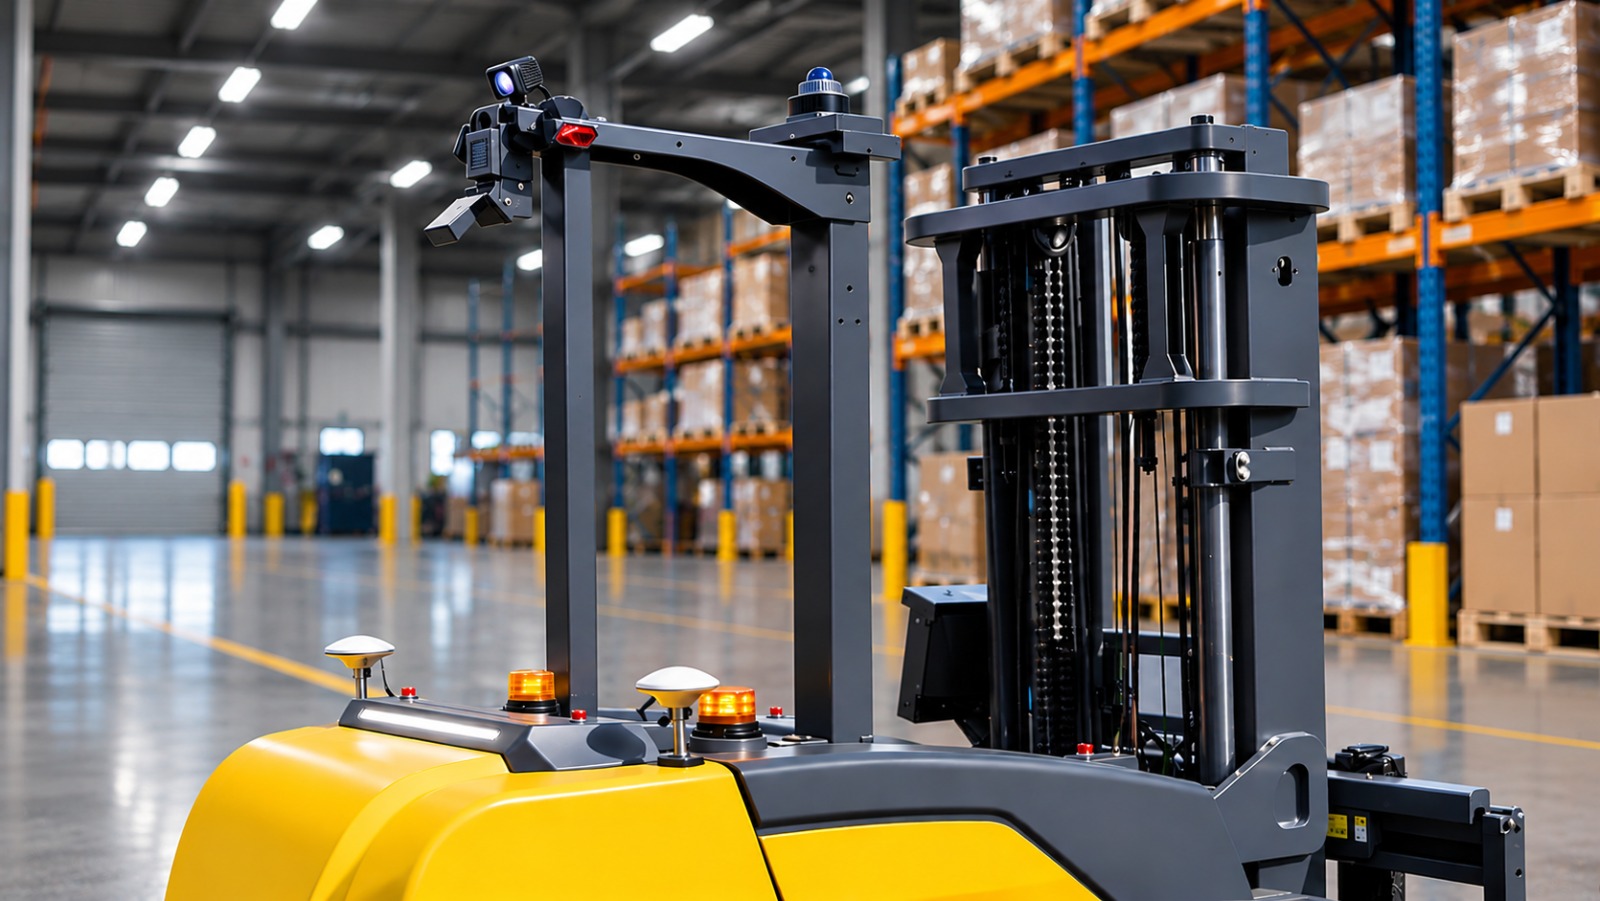
Add spatial sensing to autonomous forklifts moving materials through busy warehouse and factory routes.
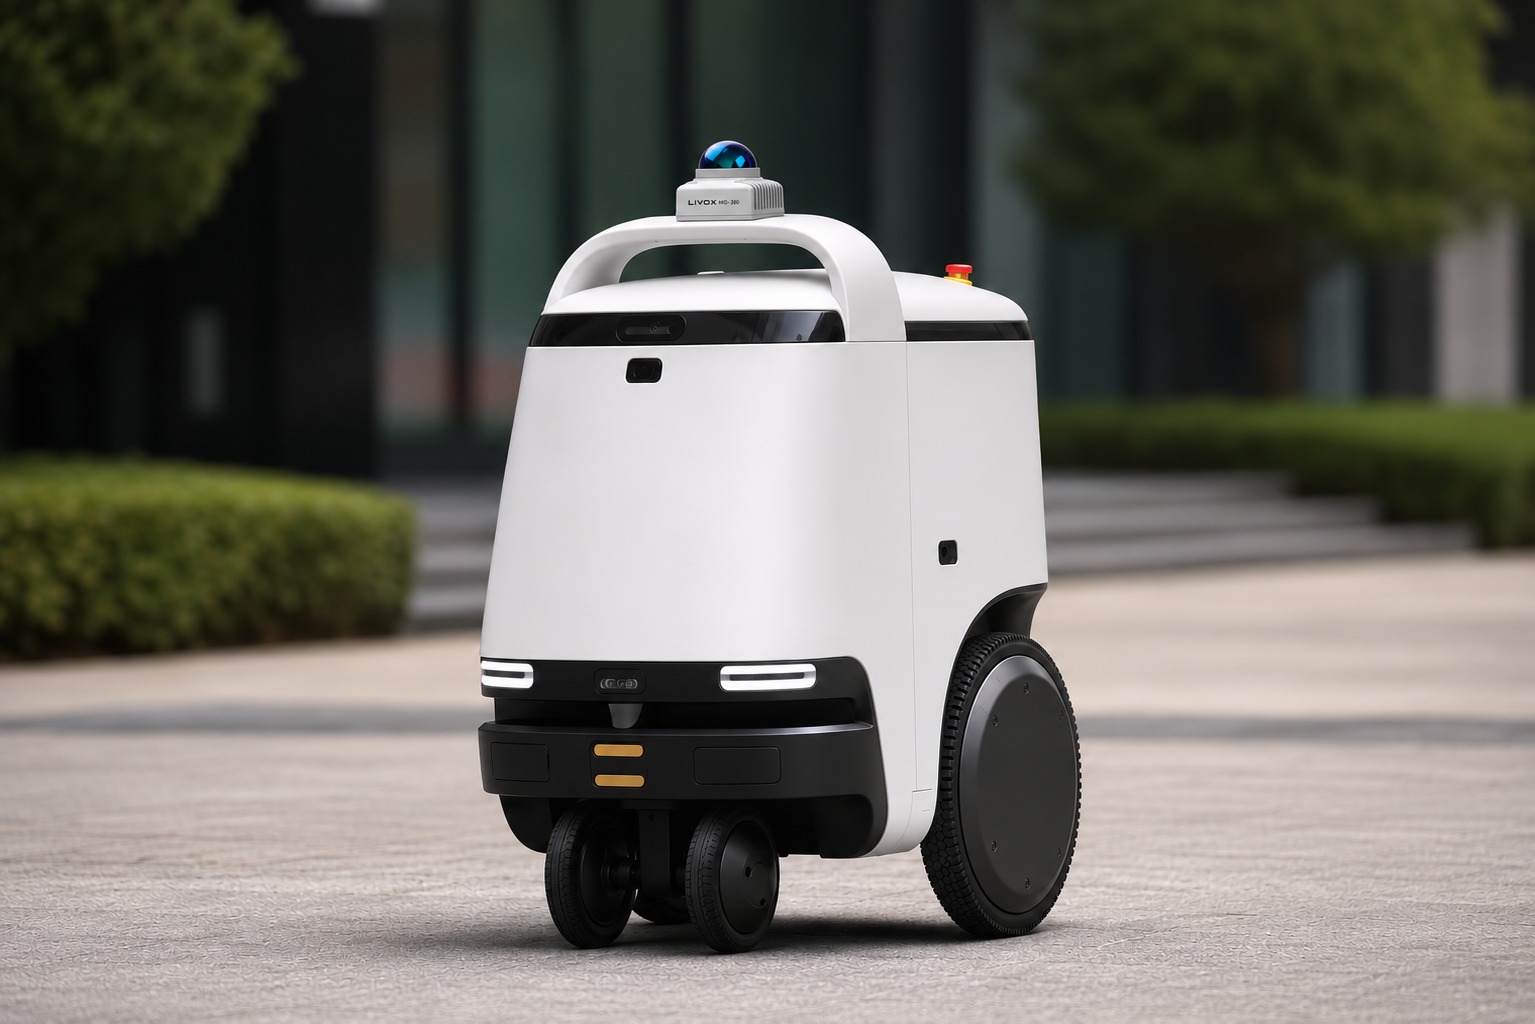
Support indoor service robots with compact 3D environmental data for navigation-related software.
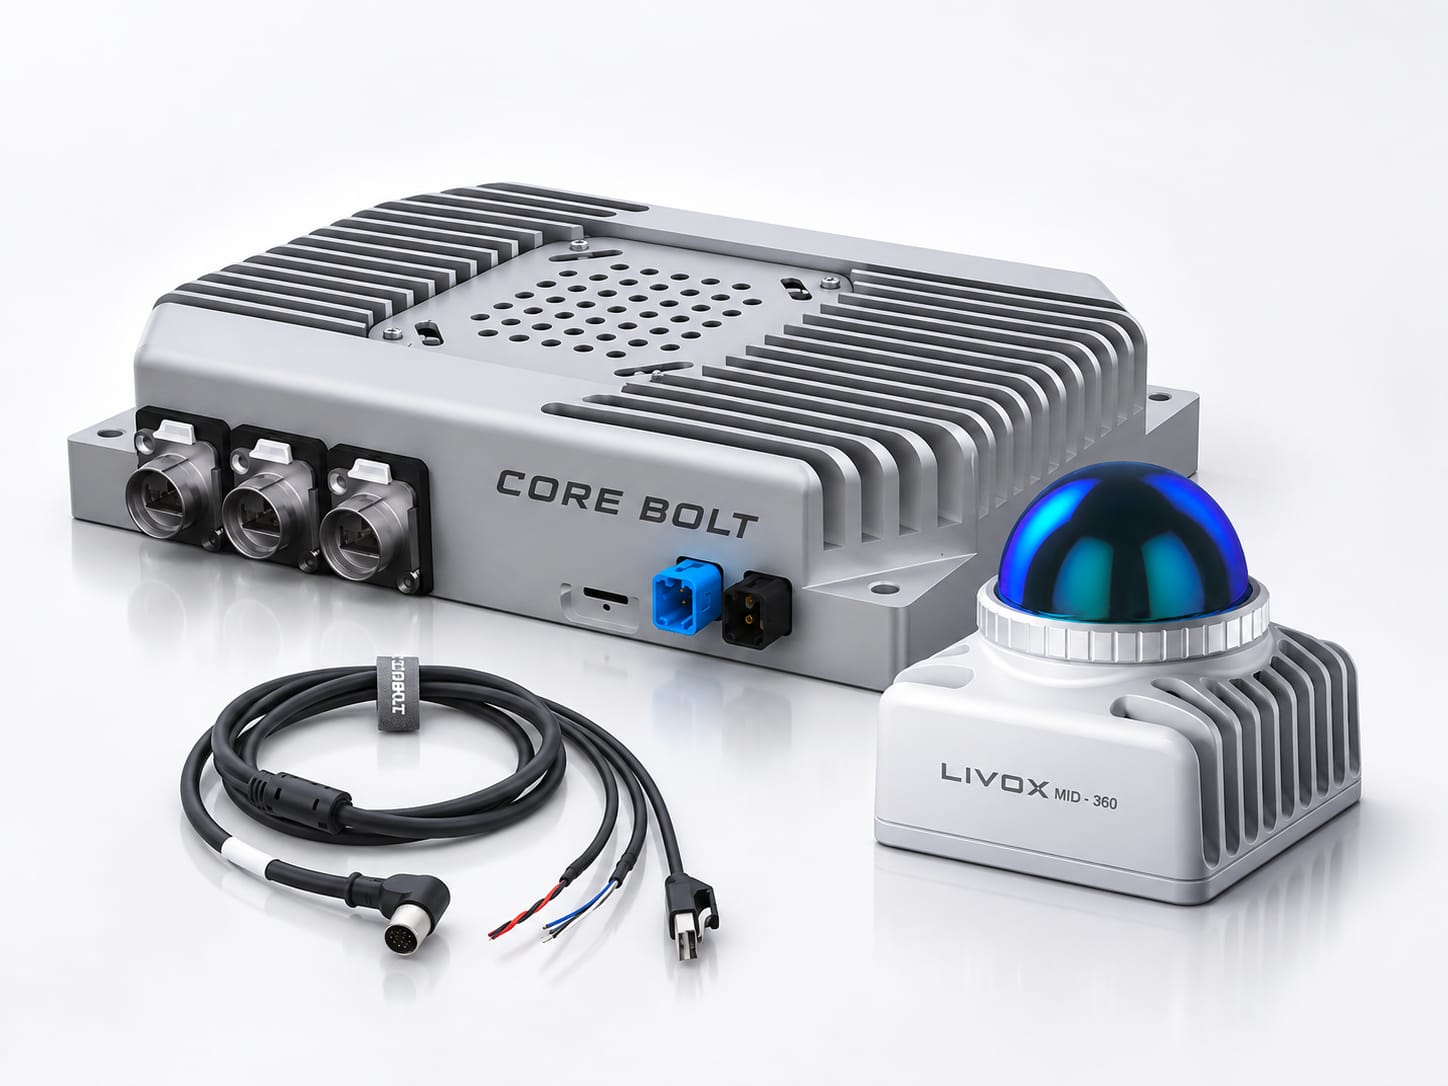
Connect LiDAR data to compatible edge computing and software for mobile-robot perception workflows.
The MID-360S is a 3D LiDAR sensor designed for low-speed mobile robotics. Its point-cloud data can be used by compatible systems for environmental mapping, localisation and obstacle-avoidance workflows.
Yes. Livox positions the MID-360S for mobile-robot applications, and CORE BOLT identifies AMR and AGV navigation as relevant use cases. Final suitability depends on sensor placement, the robot architecture and the navigation software.
A 3D LiDAR measures surrounding objects and surfaces and outputs point-cloud data. A compatible mapping and localisation stack can use that data to build an environmental representation; obstacle-avoidance behaviour is handled by the robot's software and control architecture.
The CORE BOLT product listing specifies a 360° × 59° field of view. Refer to the current Livox technical documentation for the precise horizontal and vertical field-of-view definition and operating notes.
The CORE BOLT listing states 40 m at 10% reflectivity and 70 m at 80% reflectivity. Detection performance depends on target reflectivity and test conditions. Check the current model-specific Livox specification sheet before final system design.
No. The MID-360S is a LiDAR sensor that supplies measurement data. SLAM, localisation, path planning, obstacle-avoidance decisions and motion control require compatible software and other system components.
Check the sensor's mounting position, field-of-view coverage, power supply, data interface, environmental conditions and compatibility with your compute platform and software. Confirm the current interface and installation details in the Livox user manual.
Discuss your AMR, AGV or service-robot application with CORE BOLT and review the Livox MID-360S product details before you order.